2026
A survey published in the International Journal of Robotics Research (IJRR) was featured as the most-read paper published in 2026. (It ranks third among all papers, as of September 25, 2026.)
IJRR's “Most Read” Page
We made two presentations at the Annual Conference of the Robotics Society of Japan.
Yuki Kasuga received the JSME Outstanding Presentation Award for Young Fellows.
JSME Outstanding Presentation Award for Young Fellows
One poster was presented at the Robotics and Mechatronics Conference 2026 in Fukuoka, Japan.
We presented poster presentation at the ICRA 2026 workshop held in Vienna.
The publication of the following paper has been accepted in Advanced Robotics.
R. Oishi, S. Sakaino, and T. Tsuji, “Unsupervised motion primitive identification under translational physical constraints in contact-rich tasks”,
Advanced Robotics, pp. 1-14, 2026.
R. Oishi, S. Sakaino, and T. Tsuji, “Unsupervised motion primitive identification under translational physical constraints in contact-rich tasks”,
Advanced Robotics, pp. 1-14, 2026.
Hiromitsu Toyoda was awarded the SICE Outstanding Student Award by the Society of Instrument and Control Engineers for the 2025 academic year.
SICE Outstanding Student Award
SICE Outstanding Student Award
We presented three oral presentations and one poster presentation at SAMCON 2026, held in South Korea.
The following original research paper has been accepted for publication in the peer-reviewed IEEJ Journal of Industry Applications.
H. Takahashi, T. Tsuji: "Bipedal Gait Analysis with Segmentation Using a Single Force Plate,"
IEEJ Journal of Industry Applications, Vol. 15, No. 4, 2025.
H. Takahashi, T. Tsuji: "Bipedal Gait Analysis with Segmentation Using a Single Force Plate,"
IEEJ Journal of Industry Applications, Vol. 15, No. 4, 2025.
2025
We have uploaded a demo video scheduled for exhibition at CEATEC 2025 (October 14-17, 2025).
Physical AI Robot Inheriting the Artistry of Design Polishing【CEATEC2025】
Physical AI Robot Inheriting the Artistry of Design Polishing【CEATEC2025】
The following original research paper has been accepted for publication in the peer-reviewed Journal of the Robotics Society of Japan.
T. Iizuka, R. Oishi, and T. Tsuji: “Imitative Learning of Flexible Object Grasping Using Object Rigidity Information,”
Journal of the Robotics Society of Japan, Vol. 44, No. 4, 2026. (in Japanese)
T. Iizuka, R. Oishi, and T. Tsuji: “Imitative Learning of Flexible Object Grasping Using Object Rigidity Information,”
Journal of the Robotics Society of Japan, Vol. 44, No. 4, 2026. (in Japanese)
We have uploaded a demo video scheduled for exhibition at CEATEC 2025 (October 14-17, 2025).
Imitation and Editing of Human Motor Skills
Imitation and Editing of Human Motor Skills
Our laboratory will be exhibiting at CEATEC 2025 (October 14-17, 2025)!
We presented one paper at the Conference on Robot Learning 2025 (CoRL2025).
Associate Professor Toshiaki Tsuji received the Nagamori Award.
The 11th Nagamori Awards Ceremony
We made one presentation at the Annual Conference of the Robotics Society of Japan.
Two presentations were made at the IEEJ Industrial Applications Division Conference.
Four posters were presented at the Robotics and Mechatronics Conference 2025 in Yamagata, Japan.
Four poster presentations and one oral presentation were made at the Motor and Motion Control Research Meeting (MMC) held in Gotemba Highlands, Shizuoka, Japan.
One presentation was made at ICRA2025 in Atlanta.
The following original research paper has been accepted for publication in the peer-reviewed IEEJ Journal of Industry Applications.
K. Hoshi, T. Tsuji: "Development of a Cylindrical 6-axis Force Sensor with Optimal Isotropy,"
IEEJ Journal of Industry Applications, Vol. 14, No. 5, 2025.
K. Hoshi, T. Tsuji: "Development of a Cylindrical 6-axis Force Sensor with Optimal Isotropy,"
IEEJ Journal of Industry Applications, Vol. 14, No. 5, 2025.
The publication of the following paper has been accepted in IEEE Access.
T. Tsuji: "Mamba as a Motion Encoder for Robotic Imitation Learning,"
IEEE Access, Vol. 13, pp. 69941-69949, 2025.(Open Access: https://ieeexplore.ieee.org/document/10966860).
T. Tsuji: "Mamba as a Motion Encoder for Robotic Imitation Learning,"
IEEE Access, Vol. 13, pp. 69941-69949, 2025.(Open Access: https://ieeexplore.ieee.org/document/10966860).
Shiho Inaba received the FY2024 IEEJ Women's Activity Encouragement Award in Electrical Science and Engineering.
IEEJ Electrical Science and Engineering Promotion Award / Women's Activity Encouragement Award
IEEJ Electrical Science and Engineering Promotion Award / Women's Activity Encouragement Award
The following original research paper has been published in the peer-reviewed Journal of the Robotics Society of Japan.
R. Shibuya, H. Kitaguchi, K. Kurashima, H. Hasunuma, T. Tsuji: “Detection of cable binding position based on integration of visual and force sensing,”
Journal of the Robotics Society of Japan, Vol. 42, ROMBUNNO. 1E1-02, 2025 (accepted). (in Japanese)
R. Shibuya, H. Kitaguchi, K. Kurashima, H. Hasunuma, T. Tsuji: “Detection of cable binding position based on integration of visual and force sensing,”
Journal of the Robotics Society of Japan, Vol. 42, ROMBUNNO. 1E1-02, 2025 (accepted). (in Japanese)
The following original research paper has been published in the peer-reviewed Journal of the Robotics Society of Japan.
R. Watanabe, T. Tsuji: “Deformed tactile presentation using frequency analysis,”
Journal of the Robotics Society of Japan, Vol. 42, ROMBUNNO. 3K1-05, 2025 (accepted). (in Japanese)
R. Watanabe, T. Tsuji: “Deformed tactile presentation using frequency analysis,”
Journal of the Robotics Society of Japan, Vol. 42, ROMBUNNO. 3K1-05, 2025 (accepted). (in Japanese)
2024
One presentation was made at the 25th Conference of the Society of Instrument and Control Engineers, Systems Integration Division.
One presentation was made at the 6th Annual Conference of the Japanese Society for Regenerative Medicine and Rehabilitation Science.
Three presentations were made at the 42nd Annual Conference of the Robotics Society of Japan.
Two presentations were made at the IEEJ Industrial Applications Division Conference.
The following original research paper has been published in the peer-reviewed IEEJ Journal of Industry Applications.
R. Shibuya, T. Tsuji: "Estimation of Arm Stiffness Using Force Information of a Hand in Contact with a Highly Rigid Environment,"
IEEJ Journal of Industry Applications, Vol. 13, pp. 41-49, 2024.
R. Shibuya, T. Tsuji: "Estimation of Arm Stiffness Using Force Information of a Hand in Contact with a Highly Rigid Environment,"
IEEJ Journal of Industry Applications, Vol. 13, pp. 41-49, 2024.
The following original research paper has been published in the peer-reviewed Journal of the Robotics Society of Japan.
Toshiaki Tsuji, Yasunari Kato: “Admittance Control of Multi-Degree-of-Freedom Robots Using Asymmetric Matrices,”
Journal of the Robotics Society of Japan, Vol. 42, No. 5, pp. 459-468, 2024.
Toshiaki Tsuji, Yasunari Kato: “Admittance Control of Multi-Degree-of-Freedom Robots Using Asymmetric Matrices,”
Journal of the Robotics Society of Japan, Vol. 42, No. 5, pp. 459-468, 2024.
The following original research paper has been published in the peer-reviewed Journal of the Robotics Society of Japan.
Ryoga Oishi, Toshiaki Tsuji: “Contact State Estimation of Peg-in-Hole Tasks Based on Force Coordinate Transformation Using Principal Component Analysis,”
Journal of the Robotics Society of Japan, Vol. 42, No. 5, pp. 489-492, 2024.
Ryoga Oishi, Toshiaki Tsuji: “Contact State Estimation of Peg-in-Hole Tasks Based on Force Coordinate Transformation Using Principal Component Analysis,”
Journal of the Robotics Society of Japan, Vol. 42, No. 5, pp. 489-492, 2024.
One presentation was made at AIM2024 in Boston.
Two presentations were made at ICRA 2024 in Yokohama, Japan.
Takamasa Kawahara was awarded the SICE Outstanding Student Award by the Society of Instrument and Control Engineers for the 2023 academic year.
SICE Outstanding Student Award
SICE Outstanding Student Award
2023
Takuma Kawaguchi was awarded the Saitama University Student Award for the 2023 academic year.
Saitama University Student Award
Saitama University Student Award
One presentation was made at SAMCON2024 in Kyoto, Japan.
The following original research paper has been published in the peer-reviewed IEEE Open Journal of Engineering in Medicine and Biology.
Y. Kato, T. Tsuji, and I. Cikajlo: “Feedback Type May Change the EMG Pattern and Kinematics During Robot Supported Upper Limb Reaching Task,”
IEEE Open Journal of Engineering in Medicine and Biology, Vol. 5, pp. 173-179, 2024.
Y. Kato, T. Tsuji, and I. Cikajlo: “Feedback Type May Change the EMG Pattern and Kinematics During Robot Supported Upper Limb Reaching Task,”
IEEE Open Journal of Engineering in Medicine and Biology, Vol. 5, pp. 173-179, 2024.
An article on our motion generation based on contact state estimation was published in the Nikkei.
NIKKEI Tech Foresight
NIKKEI XTECH
NIKKEI Tech Foresight
NIKKEI XTECH
An article on our control based on grinding sound was published in the Nikkan Kogyo Shimbun.
Online edition
Newswitch
YouTube
Online edition
Newswitch
YouTube
An article on our motion generation based on contact state estimation was published in the Nikkan Kogyo Shimbun.
Online edition
Online edition
The publication of the following paper has been accepted in Robotics and Automation Letters.
T. Kawahara and T. Tsuji: “Development of an Easy-to-Cut Six-Axis Force Sensor,”
IEEE Robotics and Automation Letters, Vol. 9, No. 1, pp. 563-570, 2024.
T. Kawahara and T. Tsuji: “Development of an Easy-to-Cut Six-Axis Force Sensor,”
IEEE Robotics and Automation Letters, Vol. 9, No. 1, pp. 563-570, 2024.
Our laboratory will exhibit at the International Robot Exhibition 2023 (2023/11/29 - 12/2).
An article on our asymmetric stiffness control was published in the Nikkan Kogyo Shimbun.
Online edition
Online edition
1 presentation at IROS2023 in Detroit
We presented 1 study in JSRMR2023.
We presented 5 studies in RSJ 2023.
We presented 1 study in 2023 IEE-Japan Industry Applications Society Conference.
The following review article has been published in the Journal of the Society of Instrument and Control Engineers.
T. Tsuji: “Force Sensing for Contact-Rich Tasks,”
Journal of the Society of Instrument and Control Engineers, Vol. 62, No. 8, pp. 461-466, 2023. (in Japanese)
T. Tsuji: “Force Sensing for Contact-Rich Tasks,”
Journal of the Society of Instrument and Control Engineers, Vol. 62, No. 8, pp. 461-466, 2023. (in Japanese)
The publication of the following paper has been accepted in Robotics and Automation Letters.
K. Sugawara, S. Sakaino, and T. Tsuji: “Unsupervised human motion segmentation based on characteristic force signals of contact events,”
IEEE Robotics and Automation Letters, Vol. 8, No. 10, pp. 6203-6210, 2023.
K. Sugawara, S. Sakaino, and T. Tsuji: “Unsupervised human motion segmentation based on characteristic force signals of contact events,”
IEEE Robotics and Automation Letters, Vol. 8, No. 10, pp. 6203-6210, 2023.
At ROBOMECH, the following presentation was selected for the JSME Outstanding Presentation Award for Young Fellows and the ROBOMECH Award (Academic Research Category).
T. Kawaguchi, T. Tsuji: “Contact Force Estimation from Grinding Sound Based on Frequency Analysis and Machine Learning,” Robotics and Mechatronics Conference 2022 (ROBOMECH2022), 2022. (in Japanese)
T. Kawaguchi, T. Tsuji: “Contact Force Estimation from Grinding Sound Based on Frequency Analysis and Machine Learning,” Robotics and Mechatronics Conference 2022 (ROBOMECH2022), 2022. (in Japanese)
We presented 5 studies in ROBOMECH2023.
The publication of the following paper has been accepted in Journal of Robotics and Mechatronics.
T. Kawahara and T. Tsuji: “Development of High Dynamic Range Six-Axis Force Sensor with Simple Structure,”
Journal of Robotics and Mechatronics, Vol. 35, No. 3, pp. 771-779, 2023.
T. Kawahara and T. Tsuji: “Development of High Dynamic Range Six-Axis Force Sensor with Simple Structure,”
Journal of Robotics and Mechatronics, Vol. 35, No. 3, pp. 771-779, 2023.
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
K. Takeuchi, S. Sakaino, and T. Tsuji: “Motion Generation Based on Contact State Estimation Using Two-stage Clustering,”
IEEJ Journal of Industry Applications, 2023.
K. Takeuchi, S. Sakaino, and T. Tsuji: “Motion Generation Based on Contact State Estimation Using Two-stage Clustering,”
IEEJ Journal of Industry Applications, 2023.
Yuya Nogi received the SICE Outstanding Student Award.
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
Y. Kato, S. Sakaino, and T. Tsuji: “Motion Planning for Cutting Flexible Objects Based on Contact State Recognition,”
IEEJ Journal of Industry Applications, 2023.
Y. Kato, S. Sakaino, and T. Tsuji: “Motion Planning for Cutting Flexible Objects Based on Contact State Recognition,”
IEEJ Journal of Industry Applications, 2023.
2022
The publication of the following paper has been accepted in IEEE/ASME Transactions on Mechatronics.
H. Unten, S. Sakaino, and T. Tsuji: “Peg-in-Hole Using Transient Information of Force Response,”
IEEE/ASME Transactions on Mechatronics, 2022.
H. Unten, S. Sakaino, and T. Tsuji: “Peg-in-Hole Using Transient Information of Force Response,”
IEEE/ASME Transactions on Mechatronics, 2022.
The publication of the following paper has been accepted in IEEE Access.
Y. Nogi, S. Sakaino, and T. Tsuji: “Contact Force Detection of Grinding Process Using Frequency Information and Differential Feature on Force Signal,”
IEEE Access, Vol. 10, pp. 127140-127148, 2022.(Open Access: https://ieeexplore.ieee.org/document/9968258).
Y. Nogi, S. Sakaino, and T. Tsuji: “Contact Force Detection of Grinding Process Using Frequency Information and Differential Feature on Force Signal,”
IEEE Access, Vol. 10, pp. 127140-127148, 2022.(Open Access: https://ieeexplore.ieee.org/document/9968258).
The publication of the following paper has been accepted in IEEE Access.
K. Takeuchi, K. Sugawara, I. Nojima, and T. Tsuji: “Comparative Study of Foot Fixation Methods and Sensor Arrangements in Ankle Joint Torque Measurement Equipment,”
IEEE Access, Vol. 10, pp. 114040-114047, 2022.(Open Access: https://ieeexplore.ieee.org/document/9932594).
K. Takeuchi, K. Sugawara, I. Nojima, and T. Tsuji: “Comparative Study of Foot Fixation Methods and Sensor Arrangements in Ankle Joint Torque Measurement Equipment,”
IEEE Access, Vol. 10, pp. 114040-114047, 2022.(Open Access: https://ieeexplore.ieee.org/document/9932594).
We presented 2 studies in IROS2022, Kyoto.
We presented 1 study in JSRMR2022.
We will hold an open lab information session.
Monday, October 10, 16:30-, Location: Practical Training & Research Experiment Laboratory 1st Floor, Power Electronics and Robotics laboratory(電気機器実験室).
Monday, October 10, 16:30-, Location: Practical Training & Research Experiment Laboratory 1st Floor, Power Electronics and Robotics laboratory(電気機器実験室).
We presented 3 studies in RSJ 2022.
At SAMCON 2022, the following paper was selected for the IEEJ Industry Applications Society Excellent Presentation Award.
Y. Kato, S. Sakaino, and T. Tsuji: “Motion Planning for Cutting Flexible Objects Based on Contact State Recognition,” the 8th IEEJ international workshop on Sensing, Actuation, Motion Control, and Optimization (SAMCON2022), 2022.
Y. Kato, S. Sakaino, and T. Tsuji: “Motion Planning for Cutting Flexible Objects Based on Contact State Recognition,” the 8th IEEJ international workshop on Sensing, Actuation, Motion Control, and Optimization (SAMCON2022), 2022.
The publication of the following paper has been accepted in Robotics and Automation Letters.
Y. Kato, P. Balatti, J. M. Gandarias, M. Leonori, T. Tsuji, and A. Ajoudani: “A Self-Tuning Impedance-based Interaction Planner for Robotic Haptic Exploration,”
IEEE Robotics and Automation Letters, Vol. 7, No. 4, pp. 9461-9468, 2022.
Y. Kato, P. Balatti, J. M. Gandarias, M. Leonori, T. Tsuji, and A. Ajoudani: “A Self-Tuning Impedance-based Interaction Planner for Robotic Haptic Exploration,”
IEEE Robotics and Automation Letters, Vol. 7, No. 4, pp. 9461-9468, 2022.
We presented 1 study in AIM2022, Sapporo.
We presented 4 studies in ROBOMECH2022, held in Sapporo and online.
We presented 2 studies in ICRA2022, held in Philadelphia and online.
An article, Sai-Tech Column #524 “Robots that Imitate Human Skilled Motion”, was published in the Saitama Shimbun.
We presented 3 studies in SAMCON2022, held online.
The publication of the following papers have been accepted in Robotics and Automation Letters.
・T. Horikoshi, S. Sakaino, and T. Tsuji: "High Dynamic Range Force Sensing of a Robot Hand Combining Signals on Tip and Wrist,"
IEEE Robotics and Automation Letters, Vol. 7, No. 2, pp. 3210-3217, 2022.
・Y. Nogi, S. Sakaino, and T. Tsuji: "Force Control of Grinding Process Based on Frequency Analysis,"
IEEE Robotics and Automation Letters, Vol. 7, No. 2, pp. 3250-3256, 2022.
・T. Horikoshi, S. Sakaino, and T. Tsuji: "High Dynamic Range Force Sensing of a Robot Hand Combining Signals on Tip and Wrist,"
IEEE Robotics and Automation Letters, Vol. 7, No. 2, pp. 3210-3217, 2022.
・Y. Nogi, S. Sakaino, and T. Tsuji: "Force Control of Grinding Process Based on Frequency Analysis,"
IEEE Robotics and Automation Letters, Vol. 7, No. 2, pp. 3250-3256, 2022.
2021
We presented 1 study in ICCAS2021, held online.
We presented 2 studies in IROS2021, held online.
For participants in the open lab information session:
Links to research introduction videos and more are here (in Japanese).
Links to research introduction videos and more are here (in Japanese).
We presented 3 studies in RSJ 2021.
The publication of the following paper has been accepted in Robotics and Automation Letters.
R. Tamura, T.Horikoshi, S. Sakaino, and T. Tsuji: “High Dynamic Range 6-Axis Force Sensor Employing a Semiconductor-Metallic Foil Strain Gauge Combination,”
IEEE Robotics and Automation Letters, Vol. 6, No. 4, pp. 6243-6249, 2021.
Click here to watch the video for an overview.
R. Tamura, T.Horikoshi, S. Sakaino, and T. Tsuji: “High Dynamic Range 6-Axis Force Sensor Employing a Semiconductor-Metallic Foil Strain Gauge Combination,”
IEEE Robotics and Automation Letters, Vol. 6, No. 4, pp. 6243-6249, 2021.
Click here to watch the video for an overview.
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
T. Kitamura, S. Sakaino, M. Hara, and T. Tsuji: “Bilateral Control of Human Upper Limbs Using Functional Electrical Stimulation Based on Dynamic Model Approximation,”
IEEJ Journal of Industry Applications, Vol. 10, No. 4, pp. 443-456, 2021.
T. Kitamura, S. Sakaino, M. Hara, and T. Tsuji: “Bilateral Control of Human Upper Limbs Using Functional Electrical Stimulation Based on Dynamic Model Approximation,”
IEEJ Journal of Industry Applications, Vol. 10, No. 4, pp. 443-456, 2021.
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
R. Tamura, S. Sakaino, and T. Tsuji: “High Dynamic Range Uniaxial Force/Torque Sensor Using Metal Foil and Semiconductor Strain Gauge,”
IEEJ Journal of Industry Applications, 2021.
R. Tamura, S. Sakaino, and T. Tsuji: “High Dynamic Range Uniaxial Force/Torque Sensor Using Metal Foil and Semiconductor Strain Gauge,”
IEEJ Journal of Industry Applications, 2021.
We presented 4 studies in ROBOMECH2021, held online.
The publication of the following paper has been accepted in Transactions of the Japanese Society for Medical and Biological Engineering.
K. Kubota, Y. Okubo, Y. Lee, Y. Kaneko, and T. Tsuji, “Verification of the Motor Function Improvement Effects in Patients with Chronic Stroke Hemiplegia using Tabletop Omni-Directional Driving Rehabilitation Robot”
Transactions of the Japanese Society for Medical and Biological Engineering, Vol. 59, No. 1, pp.1-6, 2021.(in Japanese)
K. Kubota, Y. Okubo, Y. Lee, Y. Kaneko, and T. Tsuji, “Verification of the Motor Function Improvement Effects in Patients with Chronic Stroke Hemiplegia using Tabletop Omni-Directional Driving Rehabilitation Robot”
Transactions of the Japanese Society for Medical and Biological Engineering, Vol. 59, No. 1, pp.1-6, 2021.(in Japanese)
The publication of the following paper has been accepted in Robotics and Automation Letters.
T. Tsuji, K. Sato, and S. Sakaino “Contact Feature Recognition Based on MFCC of Force Signals”
IEEE Robotics and Automation Letters, vol. 6, no. 3, pp. 5153-5158, 2021.
T. Tsuji, K. Sato, and S. Sakaino “Contact Feature Recognition Based on MFCC of Force Signals”
IEEE Robotics and Automation Letters, vol. 6, no. 3, pp. 5153-5158, 2021.
The following original research paper has been published in the peer-reviewed Journal of the Robotics Society of Japan.
T. Tsuji, K. Sato, and S. Sakaino: “Recognition of Contact Event Based on MFCC of Force Signals,”
Journal of the Robotics Society of Japan, Vol. 39, No. 2, pp. 173-176, 2021. (in Japanese)
T. Tsuji, K. Sato, and S. Sakaino: “Recognition of Contact Event Based on MFCC of Force Signals,”
Journal of the Robotics Society of Japan, Vol. 39, No. 2, pp. 173-176, 2021. (in Japanese)
We presented 2 studies in SAMCON2021, held online.
We presented 2 studies in ICM2021, held online.
The publication of the following paper has been accepted in Robotics and Automation Letters.
M. Oikawa, T. Kusakabe, K. Kutsuzawa, S. Sakaino, and T. Tsuji “Reinforcement Learning for Robotic Assembly Using Non-Diagonal Stiffness Matrix”
IEEE Robotics and Automation Letters, vol. 6, no. 2, pp. 2737-2744, 2021.
M. Oikawa, T. Kusakabe, K. Kutsuzawa, S. Sakaino, and T. Tsuji “Reinforcement Learning for Robotic Assembly Using Non-Diagonal Stiffness Matrix”
IEEE Robotics and Automation Letters, vol. 6, no. 2, pp. 2737-2744, 2021.
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
S. Sakaino, T. Kitamura, N. Mizukami, and T. Tsuji “High-Precision Control for Functional Electrical Stimulation Utilizing a High-Resolution Encoder”
IEEJ Journal of Industry Applications, Vol. 10, No. 2, pp. 124-133, 2021.
S. Sakaino, T. Kitamura, N. Mizukami, and T. Tsuji “High-Precision Control for Functional Electrical Stimulation Utilizing a High-Resolution Encoder”
IEEJ Journal of Industry Applications, Vol. 10, No. 2, pp. 124-133, 2021.
The publication of the following paper has been accepted in IEEE Access.
A. Sasagawa, K. Fujimoto, S. Sakaino, and T. Tsuji “Motion Generation Using Bilateral Control-based Imitation Learning with Autoregressive Learning”
IEEE Access, Vol. 9, 2021.(Open Access: https://ieeexplore.ieee.org/document/9344611).
A. Sasagawa, K. Fujimoto, S. Sakaino, and T. Tsuji “Motion Generation Using Bilateral Control-based Imitation Learning with Autoregressive Learning”
IEEE Access, Vol. 9, 2021.(Open Access: https://ieeexplore.ieee.org/document/9344611).
2020
The publication of the following paper has been accepted in Robotics and Automation Letters.
A. Sasagawa, K. Fujimoto, S. Sakaino, and T. Tsuji: “Imitation Learning Based on Bilateral Control for Human–Robot Cooperation,”
IEEE Robotics and Automation Letters, Vol. 5, No. 4, pp. 6169-6176, 2020.
A. Sasagawa, K. Fujimoto, S. Sakaino, and T. Tsuji: “Imitation Learning Based on Bilateral Control for Human–Robot Cooperation,”
IEEE Robotics and Automation Letters, Vol. 5, No. 4, pp. 6169-6176, 2020.
The following paper was selected for the Advanced Robotics Excellent Paper Award.
K. Kutsuzawa, S. Sakaino, and T. Tsuji: “Trajectory adjustment for nonprehensile manipulation using latent space of trained sequence-to-sequence model,”
Advanced Robotics, Vol. 33, Issue 21, pp. 1144-1154, 2019.
K. Kutsuzawa, S. Sakaino, and T. Tsuji: “Trajectory adjustment for nonprehensile manipulation using latent space of trained sequence-to-sequence model,”
Advanced Robotics, Vol. 33, Issue 21, pp. 1144-1154, 2019.
We presented 3 studies in RSJ 2020.
For participants in the open lab information session:
Links to videos and more are here (in Japanese).
Links to videos and more are here (in Japanese).
Information for open recruitment of research collaborators.
The summary is available here(in Japanese).
The summary is available here(in Japanese).
We presented 1 study in AIM2020, held online.
We presented 5 studies in ROBOMECH2020, held online.
At IEEJ SAMCON2020, the following paper was selected for the SAMCON2020 Outstanding Paper Award.
T. Tsuji, D. Okumura, R. Tamura, and S. Sakaino: "High dynamic range six-axis force / torque sensors for dexterous robots,"
the 6th IEEJ international workshop on Sensing, Actuation, Motion Control, and Optimization (SAMCON2020), IS-7.
T. Tsuji, D. Okumura, R. Tamura, and S. Sakaino: "High dynamic range six-axis force / torque sensors for dexterous robots,"
the 6th IEEJ international workshop on Sensing, Actuation, Motion Control, and Optimization (SAMCON2020), IS-7.
The publication of the following papers have been accepted in IEEJ SAMCON2020.
・T. Horikoshi, S. Sakaino, and T. Tsuji "Highly backdrivable Motion Control of a Robot with HDR 6-axis F/T Sensor"
the 6th IEEJ international workshop on Sensing, Actuation, Motion Control, and Optimization (SAMCON2020), P-18.
・T. Tsuji, D. Okumura, R. Tamura, and S. Sakaino "High dynamic range six-axis force / torque sensors for dexterous robots"
the 6th IEEJ international workshop on Sensing, Actuation, Motion Control, and Optimization (SAMCON2020), IS-7.
・T. Horikoshi, S. Sakaino, and T. Tsuji "Highly backdrivable Motion Control of a Robot with HDR 6-axis F/T Sensor"
the 6th IEEJ international workshop on Sensing, Actuation, Motion Control, and Optimization (SAMCON2020), P-18.
・T. Tsuji, D. Okumura, R. Tamura, and S. Sakaino "High dynamic range six-axis force / torque sensors for dexterous robots"
the 6th IEEJ international workshop on Sensing, Actuation, Motion Control, and Optimization (SAMCON2020), IS-7.
The publication of the following papers have been accepted in IEEE Access.
・D. Furuta, K. Kutsuzawa, S. Sakaino, and T. Tsuji "Motion Planning with Success Judgement Model based on Learning from Demonstration"
IEEE Access, 2020. (Open Access: https://ieeexplore.ieee.org/document/9064769).
・Y. Hasegawa, T. Kitamura, S. Sakaino, and T. Tsuji "Bilateral Control of Elbow and Shoulder Joints Using Functional Electrical Stimulation Between Humans and Robots"
IEEE Access, 2020. (Open Access: https://ieeexplore.ieee.org/abstract/document/8962009).
・D. Furuta, K. Kutsuzawa, S. Sakaino, and T. Tsuji "Motion Planning with Success Judgement Model based on Learning from Demonstration"
IEEE Access, 2020. (Open Access: https://ieeexplore.ieee.org/document/9064769).
・Y. Hasegawa, T. Kitamura, S. Sakaino, and T. Tsuji "Bilateral Control of Elbow and Shoulder Joints Using Functional Electrical Stimulation Between Humans and Robots"
IEEE Access, 2020. (Open Access: https://ieeexplore.ieee.org/abstract/document/8962009).
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
K. Kutsuzawa, S. Sakaino, and T. Tsuji, "Simultaneous Estimation of Contact Position and Tool Shape using Unscented Particle Filter"
IEEJ Journal of Industry Applications, vol. 9, no. 5, May 2020.
K. Kutsuzawa, S. Sakaino, and T. Tsuji, "Simultaneous Estimation of Contact Position and Tool Shape using Unscented Particle Filter"
IEEJ Journal of Industry Applications, vol. 9, no. 5, May 2020.
An article on a new cooking support system developed by our laboratory has been published in EMIRA. article
A dissertation defense by Kyo Kutsuzawa, a Ph.D. candidate in our lab, will be held on January 22 (Wed), 14:40-16:10.
The summary is available here (in Japanese).
The summary is available here (in Japanese).
Ryuya Tamura, a first-year master's student in our lab, received an award at the IEEJ Technical Meeting on Mechatronics Control for the following work.
"Development of a High Dynamic Range Uniaxial Force Sensor Using Semiconductor Strain Gauges" (in Japanese)
"Development of a High Dynamic Range Uniaxial Force Sensor Using Semiconductor Strain Gauges" (in Japanese)
2019
Handouts in the International Robot Exhibition 2019 are available here.
Each handout is also available via Projects page or Downloads page.
We presented 1 study at the IEEJ Technical Meeting on Mechatronics Control, Tokyo.
We have released videos(Japanese) introducing our research.
https://youtu.be/_MhhfgEAxsI The assembly robot with HDR force sensor
https://youtu.be/uwB69NpG6fk The robot that realizes dynamic skill movement by machine learning
https://youtu.be/fQbkWFSCRCo Realization of ultra-realism using visual and tactile reproduction VR ―Virtual reality technology indistinguishable from reality―
https://youtu.be/_MhhfgEAxsI The assembly robot with HDR force sensor
https://youtu.be/uwB69NpG6fk The robot that realizes dynamic skill movement by machine learning
https://youtu.be/fQbkWFSCRCo Realization of ultra-realism using visual and tactile reproduction VR ―Virtual reality technology indistinguishable from reality―
We will be exhibited at the International Robot Exhibition 2019 (2019/12/18 ~ 12/21).
Details are on the Projects page.
We presented 2 studies in IROS2019, Macau.
We presented 3 studies in IECON2019, Lisbon.
The publication of the following paper has been accepted in Advanced Robotics.
K. Kutsuzawa, S. Sakaino, and T. Tsuji: “Trajectory adjustment for nonprehensile manipulation using latent space of trained sequence-to-sequence model,”
Advanced Robotics, Vol. 33, Issue 21, pp. 1144-1154, 2019.
K. Kutsuzawa, S. Sakaino, and T. Tsuji: “Trajectory adjustment for nonprehensile manipulation using latent space of trained sequence-to-sequence model,”
Advanced Robotics, Vol. 33, Issue 21, pp. 1144-1154, 2019.
The publication of the following paper has been accepted in MDPI Sensors.
R. Koike, S. Sakaino, and T. Tsuji: “Hysteresis Compensation in Force/Torque Sensors Using Time Series Information,”
MDPI Sensors, Vol.19, No.19, 4259, 2019. (Open Access: https://www.mdpi.com/1424-8220/19/19/4259).
R. Koike, S. Sakaino, and T. Tsuji: “Hysteresis Compensation in Force/Torque Sensors Using Time Series Information,”
MDPI Sensors, Vol.19, No.19, 4259, 2019. (Open Access: https://www.mdpi.com/1424-8220/19/19/4259).
Kyo Kutsuzawa in our lab was awarded in SAMCON2019.
"Simultaneous Estimation of Contact Position and Tool Shape using Particle Filter"
"Simultaneous Estimation of Contact Position and Tool Shape using Particle Filter"
We presented 7 studies in ROBOMECH2019, Hiroshima.
【For students】Click here to download file explained at the lecture.
We presented 1 study in ICRA2019, Montreal.
Junya Tsunoda in our lab was awarded in ICM2019.
"Angle Measurement Using Moir`e Patterns Enlarging the Rotation in the Linear Motion"
"Angle Measurement Using Moir`e Patterns Enlarging the Rotation in the Linear Motion"
We presented 1 study in ICM2019, Ilmenau.
The publication of the following paper has been accepted in MDPI Sensors.
K. Kubota, M. Sekiya, and T. Tsuji: “Robot-Assisted Eccentric Contraction Training of the Tibialis Anterior Muscle Based on Position and Force Sensing,”
MDPI Sensors, Vol.19, No.6, 1288, 2019. (Open Access: https://www.mdpi.com/1424-8220/19/6/1288/).
K. Kubota, M. Sekiya, and T. Tsuji: “Robot-Assisted Eccentric Contraction Training of the Tibialis Anterior Muscle Based on Position and Force Sensing,”
MDPI Sensors, Vol.19, No.6, 1288, 2019. (Open Access: https://www.mdpi.com/1424-8220/19/6/1288/).
We presented 3 studies in SAMCON 2019, Chiba.
The following original research paper has been published in the peer-reviewed IEEJ Journal of Industry Applications.
J. Tsunoda, S. Sakaino, and T. Tsuji: “Development of an Angle Measurement System Using Monocular Camera and Moir`e Patterns,”
IEEJ Journal of Industry Applications, Vol.8, No.2, pp.200-206, 2019.
(Open Access: https://www.jstage.jst.go.jp/article/ieejjia/8/2/8_200/_article/-char/ja/).
J. Tsunoda, S. Sakaino, and T. Tsuji: “Development of an Angle Measurement System Using Monocular Camera and Moir`e Patterns,”
IEEJ Journal of Industry Applications, Vol.8, No.2, pp.200-206, 2019.
(Open Access: https://www.jstage.jst.go.jp/article/ieejjia/8/2/8_200/_article/-char/ja/).
The following original research paper has been published in the peer-reviewed IEEJ Journal of Industry Applications.
S. Sakaino, T. Sakuma, and T. Tsuji: "A Control Strategy for Electro-hydrostatic Actuator Considering Static Friction, Resonance, and Oil Leakage,”
IEEJ Journal of Industry Applications, Vol.8, No.2, pp.279-286, 2019.
(Open Access: https://www.jstage.jst.go.jp/article/ieejjia/8/2/8_279/_article/-char/ja/).
S. Sakaino, T. Sakuma, and T. Tsuji: "A Control Strategy for Electro-hydrostatic Actuator Considering Static Friction, Resonance, and Oil Leakage,”
IEEJ Journal of Industry Applications, Vol.8, No.2, pp.279-286, 2019.
(Open Access: https://www.jstage.jst.go.jp/article/ieejjia/8/2/8_279/_article/-char/ja/).
The publication of the following paper has been accepted in IEEE Transactions on Neural Systems & Rehabilitation Engineering.
M. Sekiya, S. Sakaino, and T. Tsuji: “Linear Logistic Regression forEstimation of Lower Limb Muscle Activations.”
IEEE Transactions on Neural Systems & Rehabilitation Engineering, Vol.27, No.3, 2019.
(Open Access: https://ieeexplore.ieee.org/document/8637973/).
M. Sekiya, S. Sakaino, and T. Tsuji: “Linear Logistic Regression forEstimation of Lower Limb Muscle Activations.”
IEEE Transactions on Neural Systems & Rehabilitation Engineering, Vol.27, No.3, 2019.
(Open Access: https://ieeexplore.ieee.org/document/8637973/).
2018
We presented 4 studies in IECON 2018, Washington D.C..
We presented 2 studies in IROS 2018, Madrid.
We presented 2 studies in Mecatronics2018, Mie.
Kyo Kutsuzawa, a second-year doctoral student in our lab, received an award at RSJ2018 for the following work.
"Verification of Disturbance Compensation Capability in Trajectory Generation Using a Sequence-to-Sequence Model" (in Japanese)
"Verification of Disturbance Compensation Capability in Trajectory Generation Using a Sequence-to-Sequence Model" (in Japanese)
We presented 1 study in RSJ2018, Aichi.
We presented 1 study in JIASC2018, Yokohama.
The publication of the following paper has been accepted in Robotics and Automation Letters.
K. Kutsuzawa, S. Sakaino, and T. Tsuji: “Sequence-to-Sequence Model for Trajectory Planning of Nonprehensile Manipulation Including Contact Model,”
IEEE Robotics and Automation Letters, 2018. (Open Access: https://ieeexplore.ieee.org/document/8410030/).
K. Kutsuzawa, S. Sakaino, and T. Tsuji: “Sequence-to-Sequence Model for Trajectory Planning of Nonprehensile Manipulation Including Contact Model,”
IEEE Robotics and Automation Letters, 2018. (Open Access: https://ieeexplore.ieee.org/document/8410030/).
We presented 8 studies in ROBOMECH2018, Kitakyusyu.
We presented 2 studies in SAMCON2018, Tokyo.
We presented 3 studies in AMC2018, Tokyo.
We published the video of HDR Force/Torque sensor "World's best performance with dynamic range 0.01N-1000N" developed in this laboratory.
Click here to see the video of the Force/Torque sensor
Click here for past videos
Force Visualization Cutting Board
Haptic desk
Rehabilitation support robot
Click here to see the video of the Force/Torque sensor
Click here for past videos
Force Visualization Cutting Board
Haptic desk
Rehabilitation support robot
2017
We presented 6 studies in IECON 2017, China.
The publication of the following paper has been accepted in Advanced Robotics.
T. Sakuma, K. Tsuda, K. Umeda, S. Sakaino, T. Tsuji: “Modeling and Resonance Suppression Control for Electro-hydrostatic Actuator as a Two-Mass Resonant System,”
Advanced Robotics, 1-11, 2017.
T. Sakuma, K. Tsuda, K. Umeda, S. Sakaino, T. Tsuji: “Modeling and Resonance Suppression Control for Electro-hydrostatic Actuator as a Two-Mass Resonant System,”
Advanced Robotics, 1-11, 2017.
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
T. Tsuji, K. Kutsuzawa, and S. Sakaino: “Optimized Trajectory Generation based on Model Predictive Control for Turning Over Pancakes,”
IEEJ Journal of Industry Applications, Vol. 7, No. 1, 2018.
T. Tsuji, K. Kutsuzawa, and S. Sakaino: “Optimized Trajectory Generation based on Model Predictive Control for Turning Over Pancakes,”
IEEJ Journal of Industry Applications, Vol. 7, No. 1, 2018.
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
K. Tsuda, T. Sakuma, K. Umeda, S. Sakaino, T. Tsuji: “Resonance-suppression Control for Electro-hydrostatic Actuator as Two-inertia System,”
IEEJ Journal of Industry Applications, Vol. 6, No. 5, 2017.
K. Tsuda, T. Sakuma, K. Umeda, S. Sakaino, T. Tsuji: “Resonance-suppression Control for Electro-hydrostatic Actuator as Two-inertia System,”
IEEJ Journal of Industry Applications, Vol. 6, No. 5, 2017.
The publication of the following paper has been accepted in IEEE Trans. on Industrial Electronics.
T. Tsuji, T. Seki, S. Sakaino: “Intrinsic Contact Sensing for Touch Interface with Movable Structure,”
IEEE Trans. on Industrial Electronics, Vol. 64, 2017.
T. Tsuji, T. Seki, S. Sakaino: “Intrinsic Contact Sensing for Touch Interface with Movable Structure,”
IEEE Trans. on Industrial Electronics, Vol. 64, 2017.
The publication of the following paper has been accepted in IEEE Transactions on Industrial Electronics.
S. Sakaino, T. Furuya, T. Tsuji: “Bilateral Control between Electric and Hydraulic Actuators Using Linearization of Hydraulic Actuator,”
IEEE Transactions on Industrial Electronics, Vol. 64, No. 6, pp. 4631-4641, 2017.
S. Sakaino, T. Furuya, T. Tsuji: “Bilateral Control between Electric and Hydraulic Actuators Using Linearization of Hydraulic Actuator,”
IEEE Transactions on Industrial Electronics, Vol. 64, No. 6, pp. 4631-4641, 2017.
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
S. Sakaino, H. Kawajiri, T. Tsuji: “Determination of Torque Distribution Ratio for Electric Bicycle with Independently Driven Front and Rear Wheels,”
IEEJ Journal of Industry Applications, Vol. 6, No. 3, pp. 223-230, 2017.
S. Sakaino, H. Kawajiri, T. Tsuji: “Determination of Torque Distribution Ratio for Electric Bicycle with Independently Driven Front and Rear Wheels,”
IEEJ Journal of Industry Applications, Vol. 6, No. 3, pp. 223-230, 2017.
The publication of the following paper has been accepted in Journal of Robotics and Mechatronics.
K. Kutsuzawa, S. Sakaino, T. Tsuji: “A Control System for a Tool Use Robot: Drawing a Circle by Educing Functions of a Compass,”
Journal of Robotics and Mechatronics, Vol. 29, No. 2, pp.395-405, 2017.
K. Kutsuzawa, S. Sakaino, T. Tsuji: “A Control System for a Tool Use Robot: Drawing a Circle by Educing Functions of a Compass,”
Journal of Robotics and Mechatronics, Vol. 29, No. 2, pp.395-405, 2017.
We presented 5 studies in ROBOMECH2017, Fukushima.
We presented 2 studies in SAMCON2017, Niigata.
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
H. Kitamura, S. Sakaino, T. Tsuji: “Contact Point Calculation on a Haptic Interface Utilizing Differentiated Force,”
IEEJ Journal of Industry Applications, Vol. 6, No. 2, pp. 150-159, 2017.
H. Kitamura, S. Sakaino, T. Tsuji: “Contact Point Calculation on a Haptic Interface Utilizing Differentiated Force,”
IEEJ Journal of Industry Applications, Vol. 6, No. 2, pp. 150-159, 2017.
The publication of the following paper has been accepted in IEEE Trans. Industrial Electronics.
N. Tojo, T. Mizoguchi, T. Kaneko, T. Tsuji, T. Shimono: “Estimation of Antagonistic Output Ratios Based on Force Distribution at End Effector of Limb,”
IEEE Trans. Industrial Electronics, Vol. 64, No. 2, pp. 1783-1792, 2017.
N. Tojo, T. Mizoguchi, T. Kaneko, T. Tsuji, T. Shimono: “Estimation of Antagonistic Output Ratios Based on Force Distribution at End Effector of Limb,”
IEEE Trans. Industrial Electronics, Vol. 64, No. 2, pp. 1783-1792, 2017.
The publication of the following paper has been accepted in Electrical Engineering in Japan.
T. Yamazaki, S. Sakaino, T. Tsuji: "Estimation and Kinetic Modeling of Human Arm using Wearable Robot Arm,"
Electrical Engineering in Japan, Vol. 199, No. 3, pp. 57-67, 2017.
T. Yamazaki, S. Sakaino, T. Tsuji: "Estimation and Kinetic Modeling of Human Arm using Wearable Robot Arm,"
Electrical Engineering in Japan, Vol. 199, No. 3, pp. 57-67, 2017.
The following paper has been published in Advanced Robotics.
K. Ogata, T. Umino, T. Nakayama, E. Ono, T. Tsuji: "Dummy humanoid robot simulating several trunk postures and abdominal shapes-Report of element technologies,"
Advanced Robotics, pp. 1-8, 2017.
K. Ogata, T. Umino, T. Nakayama, E. Ono, T. Tsuji: "Dummy humanoid robot simulating several trunk postures and abdominal shapes-Report of element technologies,"
Advanced Robotics, pp. 1-8, 2017.
The following paper has been published in ROBOMECH Journal.
S. Sakaino, T. Tsuji:"Development of friction free controller for electro-hydrostatic actuator using feedback modulator and disturbance observer,"
ROBOMECH Journal, Vol.4, No. 1, 2017.
S. Sakaino, T. Tsuji:"Development of friction free controller for electro-hydrostatic actuator using feedback modulator and disturbance observer,"
ROBOMECH Journal, Vol.4, No. 1, 2017.
2016
The publication of the following paper has been accepted in Journal of Robotics and Mechatronics.
K. Kutsuzawa, S. Sakaino, T. Tsuji: "A Control System for a Tool Use Robot: Drawing a Circle by Bringing Out Functions of a Compass,"
Journal of Robotics and Mechatronics, Vol. 29, No. 2.
K. Kutsuzawa, S. Sakaino, T. Tsuji: "A Control System for a Tool Use Robot: Drawing a Circle by Bringing Out Functions of a Compass,"
Journal of Robotics and Mechatronics, Vol. 29, No. 2.
The publication of the following paper has been accepted in IEEJ Journal of Industry Applications.
H. Kitamura, S. Sakaino, T. Tsuji: "Contact Point Calculation on a Haptic Interface Utilizing Differentiated Force,"
IEEJ Journal of Industry Applications, Vol. 6, No. 2.
H. Kitamura, S. Sakaino, T. Tsuji: "Contact Point Calculation on a Haptic Interface Utilizing Differentiated Force,"
IEEJ Journal of Industry Applications, Vol. 6, No. 2.
An article on the force sensor developed by our laboratory and WACOH-TECH has been published in Nikkan Kougyou Shinbun. article
The following paper has been published in IEEE Transactions on Industrial Electronics.
N. Tojo, T. Shimono, T. Kaneko, T. Tsuji, T. Mizoguchi: "Estimation of Antagonistic Output Ratios Based on Force Distribution at End Effector of Limb,"
IEEE Trans. on Industrial Electronics, 2016.
N. Tojo, T. Shimono, T. Kaneko, T. Tsuji, T. Mizoguchi: "Estimation of Antagonistic Output Ratios Based on Force Distribution at End Effector of Limb,"
IEEE Trans. on Industrial Electronics, 2016.
The following paper has been published in IEEE Transactions on Industrial Electronics.
T. Tsuji, T. Seki, S. Sakaino: "Intrinsic Contact Sensing for Touch Interface with Movable Structure,"
IEEE Trans. on Industrial Electronics, 2016.
T. Tsuji, T. Seki, S. Sakaino: "Intrinsic Contact Sensing for Touch Interface with Movable Structure,"
IEEE Trans. on Industrial Electronics, 2016.
Kyo Kutsuzawa in our lab was awarded in IECON 2016 for his paper entitled
"Estimation of individual force at three contact points on an end-effector by a six-axis force/torque sensor."
"Estimation of individual force at three contact points on an end-effector by a six-axis force/torque sensor."
We presented 4 studies in IECON 2016, Firenze.
We presented 3 studies in IROS 2016, Daejeon.
We presented 3 studies in RSJ 2016.
We presented 1 study in LIFE 2016.
The following paper has been published in IEEJ Journal of Industry Applications.
T. Kitamura, N. Mizukami, H. Mizoguchi, S. Sakaino, T. Tsuji: "Bilateral Control in the Vertical Direction Using Functional Electrical Stimulation"
IEEJ Journal of Industry Applications, Vol. 5, No. 5, pp. 398-404, 2016.
T. Kitamura, N. Mizukami, H. Mizoguchi, S. Sakaino, T. Tsuji: "Bilateral Control in the Vertical Direction Using Functional Electrical Stimulation"
IEEJ Journal of Industry Applications, Vol. 5, No. 5, pp. 398-404, 2016.
We presented 1 study in EMBC 2016, Florida.
The following original research paper has been published in IEEJ Transactions on Industry Applications.
T. Yamazaki, S. Sakaino, T. Tsuji: "Dynamics Modeling and Physical Parameter Estimation of the Human Arm Using a Wearable Robot Arm"
IEEJ Trans. on Industry Applications, Vol. 136, No. 4, pp. 254-262, 2016 (in Japanese)
T. Yamazaki, S. Sakaino, T. Tsuji: "Dynamics Modeling and Physical Parameter Estimation of the Human Arm Using a Wearable Robot Arm"
IEEJ Trans. on Industry Applications, Vol. 136, No. 4, pp. 254-262, 2016 (in Japanese)
We had 8 poster-presentations in ROBOMECH 2016.
We presented 1 study in ISIE 2016, California.
We presented 3 studies in AMC 2016, Auckland.
An article on our Rehabilitation system "FOVI-Bar" has been published in Nikkan Kougyou Shinbun. article
The following paper has been published in IEEE Transactions on Industrial Electronics.
T. Tsuji, T. Kaneko, S. Sakaino: "Motion Matching in Rehabilitation Databases with Force and Position Information,"
IEEE Trans. on Industrial Electronics, Vol. 63,No. 3, pp. 1935-1942, Mar. 2016.
T. Tsuji, J. Ohkuma, S. Sakaino: "Dynamic Object Manipulation Considering Contact Condition of Robot with Tool,"
IEEE Trans. on Industrial Electronics , Vol. 63,No. 3, pp. 1972-1980, Mar. 2016.
T. Tsuji, T. Kaneko, S. Sakaino: "Motion Matching in Rehabilitation Databases with Force and Position Information,"
IEEE Trans. on Industrial Electronics, Vol. 63,No. 3, pp. 1935-1942, Mar. 2016.
T. Tsuji, J. Ohkuma, S. Sakaino: "Dynamic Object Manipulation Considering Contact Condition of Robot with Tool,"
IEEE Trans. on Industrial Electronics , Vol. 63,No. 3, pp. 1972-1980, Mar. 2016.
Hiroyuki Kitamura, a first-year master's student in our lab, received the Excellent Presentation Award at IEEJ SAMCON 2016.
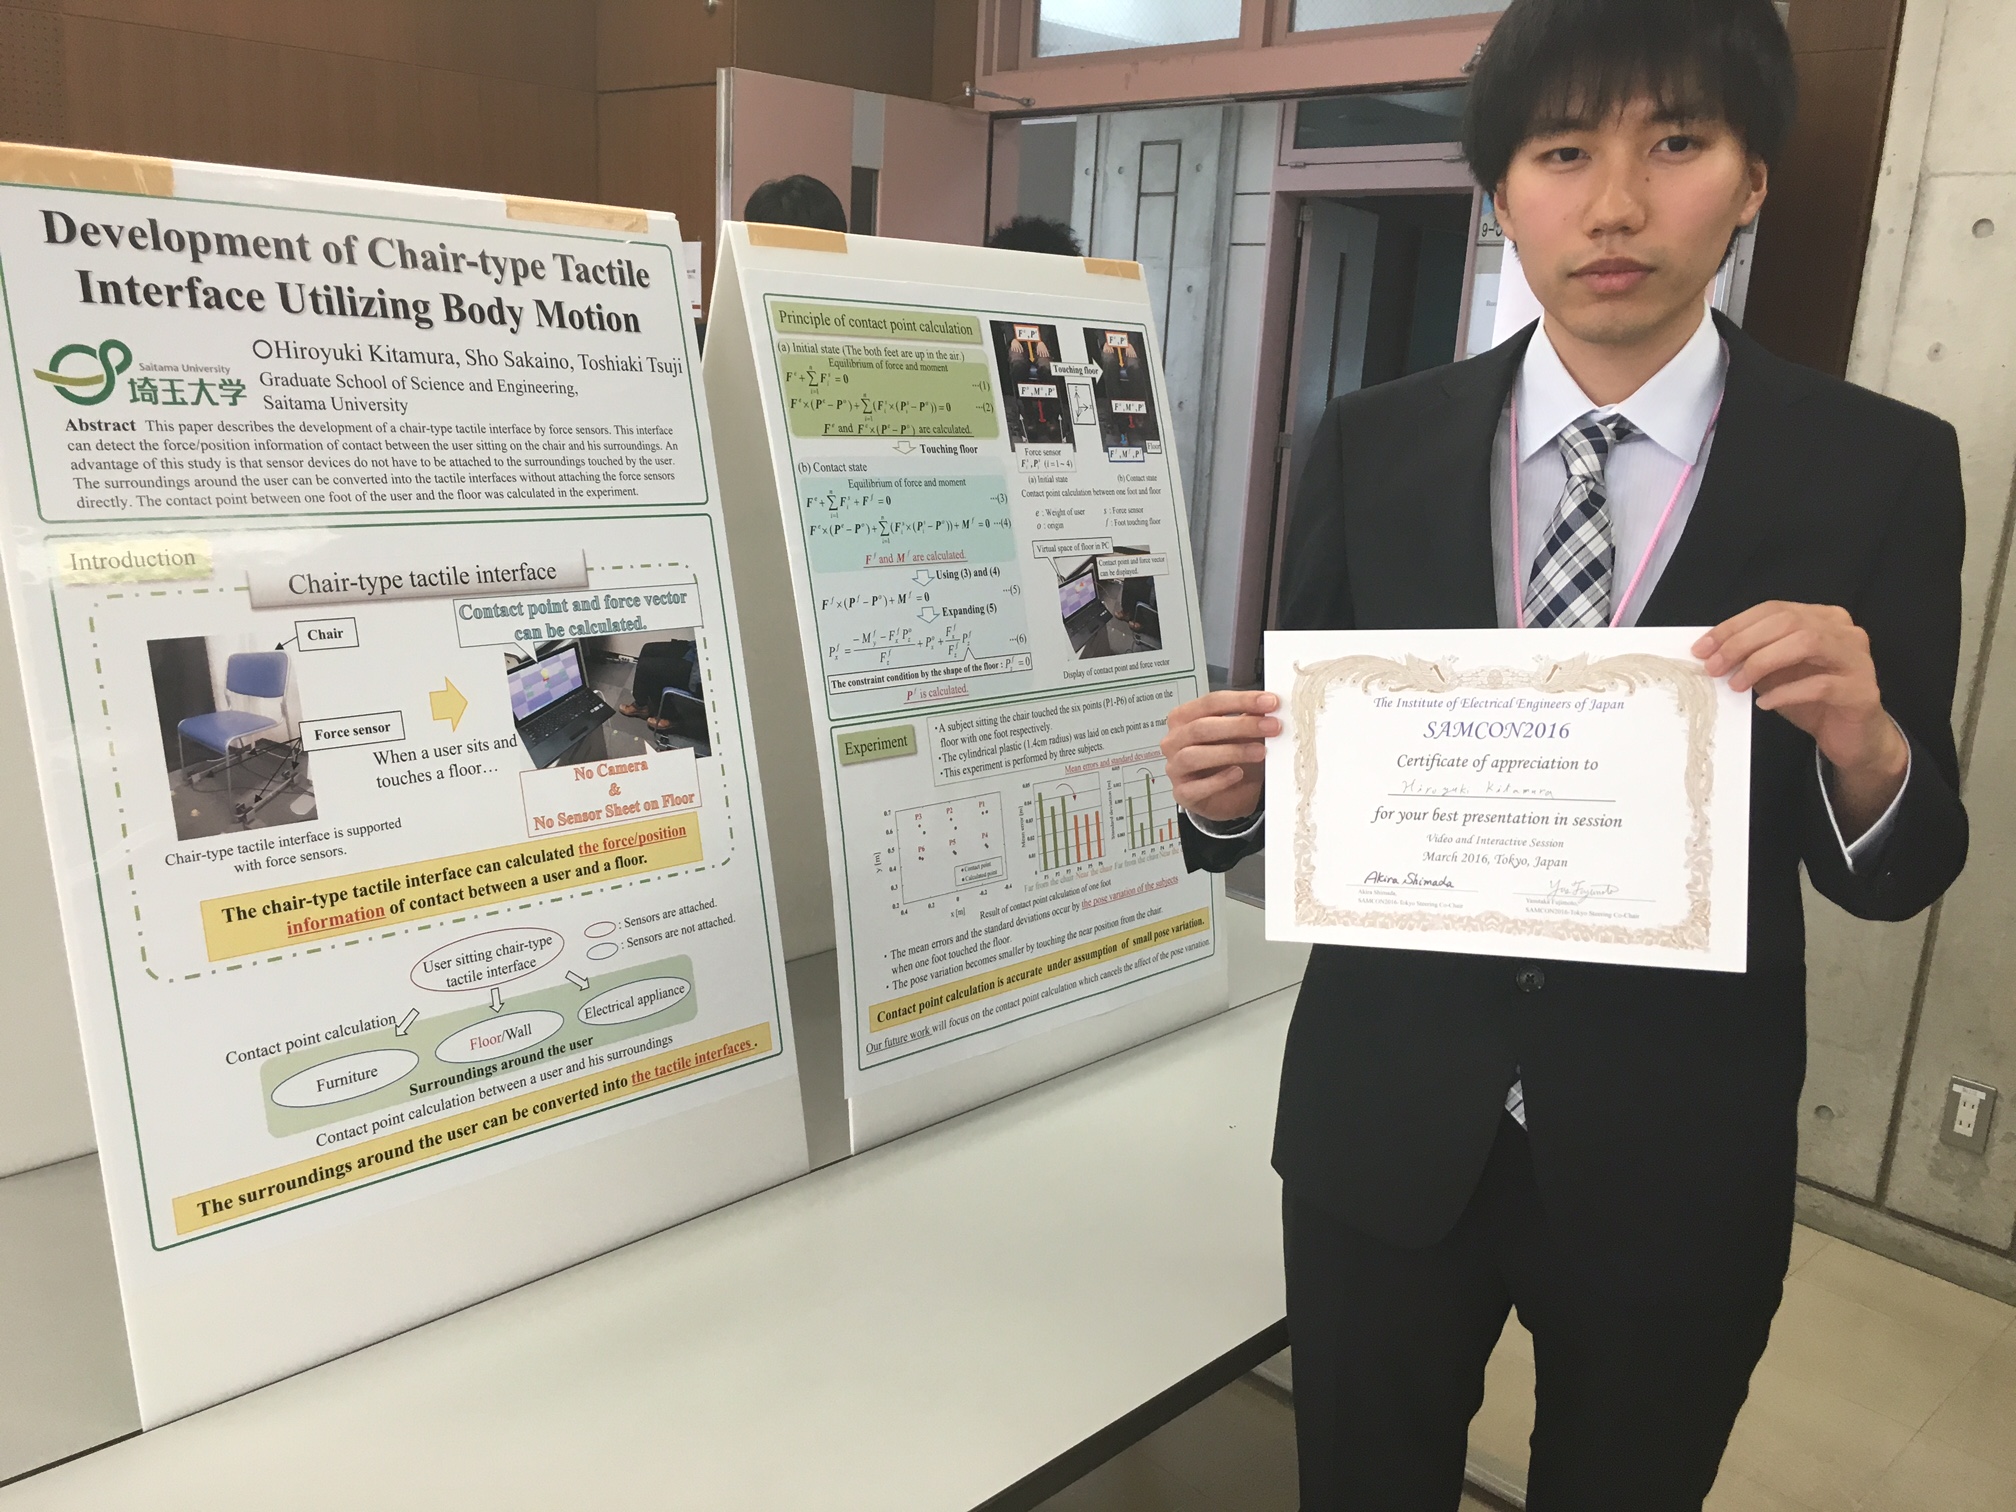
We presented 4 studies in IEEJ SAMCON 2016.
2015
We presented 2 studies in SICE SI 2015.
We presented 2 studies in ICAM 2015.
Associate Professor Tsuji received the following award.
FY2015 Saitama University Faculty of Engineering Best Lecture Award, “Robot Control”
FY2015 Saitama University Faculty of Engineering Best Lecture Award, “Robot Control”
We presented 3 studies in IECON 2015.
Our rehabilitation support device "FOVI-Bar" was featured in the Nihon Keizai Shimbun.
“Simplified type at 1/10 the installation cost: Saitama University partners with companies toward commercialization of a gait analysis device for rehabilitation”
“Simplified type at 1/10 the installation cost: Saitama University partners with companies toward commercialization of a gait analysis device for rehabilitation”
We demonstrated 2 studies in CEATEC JAPAN 2015.
We presented 1 study in IROS 2015, Hamburg.
Kunihiro Ogata, a researcher in our lab, received the RSJ Research Encouragement Award for the following work.
“Humanoid Dummy Robot with an Exterior Deformation Mechanism for the Objective Evaluation of Welfare Equipment”
“Humanoid Dummy Robot with an Exterior Deformation Mechanism for the Objective Evaluation of Welfare Equipment”
We presented 1 study in LIFE 2015.
We presented 2 studies in RSJ 2015.
We had 1 poster-presentation in ICORR 2015, Singapore.
We had 1 poster-presentation in ICRA 2015, Seattle.
We had 8 poster-presentations in ROBOMECH 2015.
We presented 4 studies in IEEJ SAMCON 2015.
We presented 2 studies in IEEE ICM 2015.
Our haptic technology was featured in the Nihon Keizai Shimbun under the following headline.
“Saitama University turns furniture and walls into switches, partnering with companies toward practical use”
“Saitama University turns furniture and walls into switches, partnering with companies toward practical use”
T. Seki, a first-year master's student in our lab, appeared on the TBS program “Mirai no Kigen” on January 11.
2014
We presented one studies in SICE SI 2014.
Prof. Toshiaki Tsuji won Best Presentation Recognition from IEEE IECON for his study.
"Development of a Desk-Type Tactile Interface Using Force Sensors"
"Development of a Desk-Type Tactile Interface Using Force Sensors"
We demonstrated 2 studies in CEATEC JAPAN 2014.
We presented 1 studies in IEEE/RSJ International Conference on Intelligent Robots and Systems.
We presented 2 studies in RSJ 2014.
We presented 2 studies at the IEEJ Industry Applications Society Conference.
We presented 1 study in IEEE/RSJ International Conference on Intelligent Robots and Systems, Chicago.
We had 1 presentation in ROBOMECH 2014.
We had 1 presentation in IPEC-Hiroshima 2014.
Associate Professor Tsuji received the JSME Young Engineers Award (Research) for the following work.
“Research on Haptic Signal Processing for Human Support Robots”
“Research on Haptic Signal Processing for Human Support Robots”
A video on Rehabilitation support robot was released in TBS.
We presented 2 studies in IEEE International Workshop AMC 2014, Yokohama.
We had 7 oral-presentaions in the Joint Technical Meeting on Industrical Instrumentation and Control and Mechatronics Control, IEEE Japan.
The Haptic Desk was featured in the “Tore-Tama” segment of TV TOKYO's “World Business Satellite.”
You can watch it on this site.
An article on haptic desk was published in Nikkei Sangyo Shinbun.
A video for understanding induction machines in Electrical Machinery I is here.
An article on Rehabilitation support robot "R-cloud" was published in Nikkei Sangyou Shinbun.
2013
The attendance assignment template file for Numerical Analysis and Algorithm Exercises is here (right-click to save).
Our rehabilitation support robot was featured in the “Tore-Tama” segment of TV TOKYO's “World Business Satellite.”
You can watch it on this site.
An introduction video of our rehabilitation support robot was published on DIGINFO TV.
English article
Japanese article
We demonstrated 3 studies in international robot exhibition.
An article on the “Haptic Desk,” a desk turned into a tactile interface, appeared on the front page of the Nikkan Kogyo Shimbun.
Online edition here
We had 1 presentation and 2 lectures in IEEE IROS 2013.
We gave 1 presentation and 3 exhibits at the JST PRESTO Symposium “Designing Future Society through Informatics,” 2nd session “Health and Wellness Opened Up by Information.”
We presented 1 study in RSJ 2013.
We had 1 oral-presentaion in IEEE R10-HTC 2013.
The following original research paper has been published in this month's Journal of Robotics and Mechatronics.
T. Tsuji, M. Yamada, Y. Kaneko: "A Robot Measuring Upper Limb Range of Motion for Rehabilitation Database,"
Journal of Robotics and Mechatronics, Vol. 25, No. 3, pp. 515-520, 2013.
T. Tsuji, M. Yamada, Y. Kaneko: "A Robot Measuring Upper Limb Range of Motion for Rehabilitation Database,"
Journal of Robotics and Mechatronics, Vol. 25, No. 3, pp. 515-520, 2013.
We had 3 poster-presentations in ROBOMECH 2013.
We had 9 oral-presentaions in the Joint Technical Meeting on Industrical Instrumentation and Control and Mechatronics Control, IEE Japan.
We had one oral-presentation in IEEE ICM 2013.
The following original research paper has been published in IEEJ Journal of Industry Applications.
M. Kamibayashi, S. Sakaino, T. Tsuji: "Evaluation Indices of Stiffness Control for Its Performance Comparison,"
IEEJ Journal of Industry Applications, Vol. 2, No. 1, pp.61-66
M. Kamibayashi, S. Sakaino, T. Tsuji: "Evaluation Indices of Stiffness Control for Its Performance Comparison,"
IEEJ Journal of Industry Applications, Vol. 2, No. 1, pp.61-66
2012
A video for understanding induction machines in Electrical Machinery I is here.
The attendance assignment template file for Numerical Analysis and Algorithm Exercises is here (right-click to save).
We had 2 oral-presentations and 1 tutorial in IEEE IECON 2012, Montreal.
We presented 1 study in IEEE/RSJ IROS 2012, Vilamoura.
2011
We presented 1 study at the Annual Conference of the Robotics Society of Japan.
The following article has been published in the September issue on IEEJ Magazine.
Toshiaki Tsuji, Kohei Ohnishi: "Motion Control Based on Musculoskeletal Actuators(in Japanese)"
Toshiaki Tsuji, Kohei Ohnishi: "Motion Control Based on Musculoskeletal Actuators(in Japanese)"
We presented two studies in JIASC 2012, Chiba.
An article on our rehabilitation support robot was published in the Saitama Shimbun.
Sai-Tech Column “Disseminating Knowledge and Technology”: “Improving Exercise Therapy by Measuring Force”
Sai-Tech Column “Disseminating Knowledge and Technology”: “Improving Exercise Therapy by Measuring Force”
We presented one study in ROBOMECH 2012, Shizuoka.
We had a simposium presentation in PSJ.
We presented 1 study in IEEE International Workshop AMC 2012, Sarajevo.
We had a simposium presentation in 2012 IEEJ annual meeting.
Naoyuki Kurita, a fourth-year undergraduate in our lab, received the Excellent Paper Presentation Award from the IEEJ Tokyo Section, Saitama Branch.
Title: “Signal Processing of a Haptic Armor with a Non-Convex End-Effector”
Title: “Signal Processing of a Haptic Armor with a Non-Convex End-Effector”
We presented 3 studies in IEEJ IIC 2012, Chiba.
Site renewal
We gave 1 presentation at IECON2011.
We organized a workshop at IECON2011.
We gave a talk at the New Technology Presentation Meeting of Four Universities in the Northern Tokyo Metropolitan Area.
We presented 2 studies at the Annual Conference of the Robotics Society of Japan.
We presented 2 studies at the IEEJ Industry Applications Society Conference.
The following original research paper has been published in IEEJ Transactions on Industry Applications.
R. Hanyu, T. Tsuji: "Development of a Whole-Body Haptic Sensor with Multiple Supporting Points and Its Application to a Manipulator"
IEEJ Trans. on Industry Applications, Vol. 131 (2011), No. 9, pp. 1128-1134 (in Japanese)
R. Hanyu, T. Tsuji: "Development of a Whole-Body Haptic Sensor with Multiple Supporting Points and Its Application to a Manipulator"
IEEJ Trans. on Industry Applications, Vol. 131 (2011), No. 9, pp. 1128-1134 (in Japanese)
We presented 1 study at ICRA2011.
We received the JSME Award.
Title:
“Dynamic Display of Facial Expressions on the Face Robot with a Life Mask”
Title:
“Dynamic Display of Facial Expressions on the Face Robot with a Life Mask”
Site renewal
We presented 2 studies at the IEEJ Technical Meeting on Industrial Instrumentation and Control.
2010
We received the Recognition Award at MECATRONICS2010.
We presented 1 study at MECATRONICS2010.
We gave an invited talk at the young researchers' seminar “New Developments in Next-Generation Power Electronics Technology,” co-hosted by the IEEJ Tokai Branch and the SICE Chubu Branch. Title: “Technologies for Robots to Detect Force and Touch with the Whole Body”
We presented 1 study at IECON2010.
We presented 3 studies at IROS2010.
We exhibited and presented our image processing research at Innovation Japan 2010.
We presented 2 studies at the Annual Conference of the Robotics Society of Japan.
We received the RSJ Research Encouragement Award.
Footage of our rehabilitation support robot and lancelet robot was broadcast on “Close-up Tohoku” (NHK Sendai, 19:30-19:55).
We presented 1 study at the IEEJ Industry Applications Society Conference (JIASC2010).
Footage of our rehabilitation support robot and lancelet robot was broadcast on “Ohayo Nippon” (NHK, 7:00-7:45).
Our rehabilitation support robot and lancelet robot were featured on “Hamanaka Aizu TODAY” (NHK Fukushima, 18:10-19:00).
We gave 1 invited talk and 2 exhibits at the International Symposium on Application of Biomechanical Control Systems to Precision Engineering.
Our rehabilitation support robot and lancelet robot were featured on “FTV Super News” (Fukushima TV, 17:55-19:00).
We presented 2 studies at the JSME Conference on Robotics and Mechatronics 2010 (ROBOMEC2010).
We presented 1 study at the IEEE International Conference on Robotics and Automation (ICRA2010).
The following original research paper has been published in the Journal of the Robotics Society of Japan.
T. Tsuji, T. Ito: "Command Recognition of Robots Based on Feature Quantity Extraction from Haptic Information," Journal of the Robotics Society of Japan, Vol. 28, No. 3, pp. 79-86 (in Japanese)
T. Tsuji, T. Ito: "Command Recognition of Robots Based on Feature Quantity Extraction from Haptic Information," Journal of the Robotics Society of Japan, Vol. 28, No. 3, pp. 79-86 (in Japanese)
We presented 2 studies at the 11th International Workshop on Advanced Motion Control (AMC2010).
R. Hanyu (second-year master's student) received the Excellent Paper Presentation Award from the IEEJ Tokyo Section, Saitama Branch Committee.
Title: “Development of a Whole-Body Haptic Sensor with Multiple Supporting Points and Its Application to a Manipulator”
Title: “Development of a Whole-Body Haptic Sensor with Multiple Supporting Points and Its Application to a Manipulator”
The following original research paper has been published in IEEJ Transactions on Industry Applications.
T. Tsuji, H. Tashiro, S. Abe: "A Counting Method of People at Elevator Lobby Focusing on Top of Moving Objects," IEEJ Trans. on Industry Applications, Vol. 130-D, No. 3, pp. 334-340 (in Japanese)
T. Tsuji, H. Tashiro, S. Abe: "A Counting Method of People at Elevator Lobby Focusing on Top of Moving Objects," IEEJ Trans. on Industry Applications, Vol. 130-D, No. 3, pp. 334-340 (in Japanese)
The following original research paper has been published in IEEJ Transactions on Industry Applications.
T. Ito, T. Tsuji: IEEJ Trans. on Industry Applications, Vol. 130-D, No. 3, pp. 293-299 (in Japanese)
T. Ito, T. Tsuji: IEEJ Trans. on Industry Applications, Vol. 130-D, No. 3, pp. 293-299 (in Japanese)
The following original research paper has been published in IEEJ Transactions on Industry Applications.
T. Tsuji, R. Inoda: "Removal of Specular Reflection Based on High-Speed Camera Images," IEEJ Trans. on Industry Applications, Vol. 130-D, No. 3, pp. 261-267 (in Japanese)
T. Tsuji, R. Inoda: "Removal of Specular Reflection Based on High-Speed Camera Images," IEEJ Trans. on Industry Applications, Vol. 130-D, No. 3, pp. 261-267 (in Japanese)
The following original research paper has been published in IEEJ Transactions on Industry Applications.
"A Counting Method of People at Elevator Lobby Focusing on Top of Moving Objects," IEEJ Trans. on Industry Applications, Vol. 130-D, No. 3, pp. 334-340 (in Japanese)
"A Counting Method of People at Elevator Lobby Focusing on Top of Moving Objects," IEEJ Trans. on Industry Applications, Vol. 130-D, No. 3, pp. 334-340 (in Japanese)
We received the Excellent Paper Presentation Award from the IEEJ Industry Applications Society Technical Committee on Industrial Instrumentation and Control.
Title: “Removal of Specular Reflection Based on High-Speed Camera Images”
Title: “Removal of Specular Reflection Based on High-Speed Camera Images”
2009
An article, “Separation Technology for Specular Reflection Using a High-Speed Camera,” was published in the October/November issue of the Saitama Employers' Association News.
We presented 1 study at the 35th Annual Conference of the IEEE Industrial Electronics Society (IECON2009).
We presented 1 study at the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2009).
We presented 2 studies at Engineering Forum 2009 (Yomiuri Shimbun).
We exhibited at Innovation Japan.
We gave 3 talks at the Annual Conference of the Robotics Society of Japan.
We received the IEEJ Excellent Paper Presentation Award.
Title: “Development of a Shell-Shaped Sensor for Whole-Body Force Sensation and Its Calibration Method”
Title: “Development of a Shell-Shaped Sensor for Whole-Body Force Sensation and Its Calibration Method”
We gave 3 talks at the IEEJ Industry Applications Society Conference.
The following original research paper has been published in IEEJ Transactions on Industry Applications.
H. Uchidate, R. Inoda, T. Tsuji, S. Abe: "Counting People and Recognition of Wheelchairs at Elevator Lobby by Real-time Image Processing," IEEJ Trans. on Industry Applications, Vol. 129-D, No. 6, pp. 578-584 (in Japanese)
H. Uchidate, R. Inoda, T. Tsuji, S. Abe: "Counting People and Recognition of Wheelchairs at Elevator Lobby by Real-time Image Processing," IEEJ Trans. on Industry Applications, Vol. 129-D, No. 6, pp. 578-584 (in Japanese)
We presented 1 study at the Conference on Robotics and Mechatronics (ROBOMEC2009).
The following original research paper has been published in IEEE Trans. on Industrial Electronics.
T. Tsuji, Y. Kaneko, S. Abe: "Whole-body Force Sensation by Force Sensor with Shell-shaped End-effector," IEEE Trans. on Industrial Electronics, Vol. 56, No. 5, pp.1375-1382
T. Tsuji, Y. Kaneko, S. Abe: "Whole-body Force Sensation by Force Sensor with Shell-shaped End-effector," IEEE Trans. on Industrial Electronics, Vol. 56, No. 5, pp.1375-1382
We presented 1 study at the IEEE International Conference on Mechatronics (ICM2009).
We presented 3 studies at the IEEJ Technical Meeting on Industrial Instrumentation and Control.
The following original research paper has been published in IEEE Trans. on Industrial Electronics.
T. Tsuji, T. Hashimoto, H. Kobayashi, M. Mizuochi, K. Ohnishi: “A Wide-range Velocity Measurement Method for Motion Control,” IEEE Trans. on Industrial Electronics, Vol. 56, No. 2, pp. 510-519
T. Tsuji, T. Hashimoto, H. Kobayashi, M. Mizuochi, K. Ohnishi: “A Wide-range Velocity Measurement Method for Motion Control,” IEEE Trans. on Industrial Electronics, Vol. 56, No. 2, pp. 510-519
The following original research paper has been published in the Transactions of the Japan Society of Mechanical Engineers, Series C.
T. Hashimoto, S. Hiramatsu, T. Tsuji, H. Kobayashi: "Dynamic Display of Facial Expressions on the Face Robot with a Life Mask," Trans. of the Japan Society of Mechanical Engineers, Series C, Vol. 75, No. 749, pp. 113-121 (in Japanese)
T. Hashimoto, S. Hiramatsu, T. Tsuji, H. Kobayashi: "Dynamic Display of Facial Expressions on the Face Robot with a Life Mask," Trans. of the Japan Society of Mechanical Engineers, Series C, Vol. 75, No. 749, pp. 113-121 (in Japanese)
The following original research paper has been published in the IEICE Transactions on Information and Systems (Japanese Edition).
Y. Nishikawa, T. Tsuji, Y. Kaneko, S. Abe: "kdm-tree: A Region Splitting Tree Structure Suitable for Frequent Update of Moving Objects," The IEICE Trans. on Information and Systems, Vol. J92-D, No. 1, pp. 1-11 (in Japanese)
Y. Nishikawa, T. Tsuji, Y. Kaneko, S. Abe: "kdm-tree: A Region Splitting Tree Structure Suitable for Frequent Update of Moving Objects," The IEICE Trans. on Information and Systems, Vol. J92-D, No. 1, pp. 1-11 (in Japanese)
2008
H. Uchidate (alumnus; a second-year master's student at the time of the presentation) received the Excellent Paper Presentation Award from the IEEJ Industry Applications Society Technical Committee on Industrial Instrumentation and Control.
T. Ito (fourth-year undergraduate) received the Special Award from the Organizing Committee of the 5th IEEE Tokyo Young Researcher Workshop.