Haptic Signal Processing
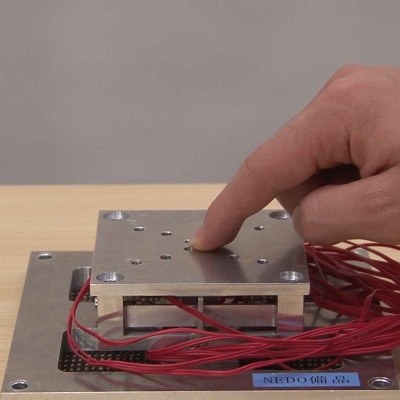
Development of high dynamic range six-axis force sensor
In recent years, an increasing number of robots are equipped with force sensors and perform advanced assembly tasks while adjusting their force. Robots that must perform a wide variety of motions require force sensors with a wide detection range (dynamic range). Therefore, we have been developing a high dynamic range (HDR) force sensor.
Reference material
[in Japanese]クロスアーチの導入によるHDR6軸力覚センサの小型化
Assembly Using Machine Learning
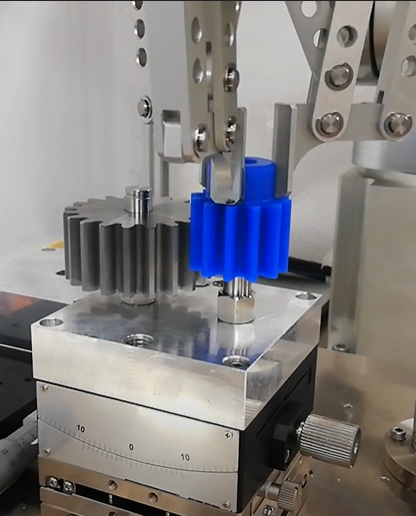
Assembly Using Reinforcement Learning
There is an increased demand for task automation using robots.
In our laboratory, we have achieved realizing precise assembly tasks such as peg-in-hole tasks and gear-insertion tasks by robots applied reinforcement learning (RL).
The details can be seen in the following paper.
http://arxiv.org/abs/2002.12207
Success/Failure Identification by Neural Network
In the case of assembly tasks required high precision, the success rate of tasks can be improved by recognizing the task failure through success/failure identification and executing the task again when it fails.
Therefore, the force information of successful cases of task execution is detected, and the success/failure of the task is judged using machine learning.
If the assembly task is not succeeded, success/failure identification enables robots to modify its operation and re-execute the task. This leads to higher reliability of the assembly tasks by robots.
Reference material
[in Japanese]微小な力感覚を認識するAI技術によってロボットの組み立ての信頼性向上
Rehabilitation support
Rehabilitation robot
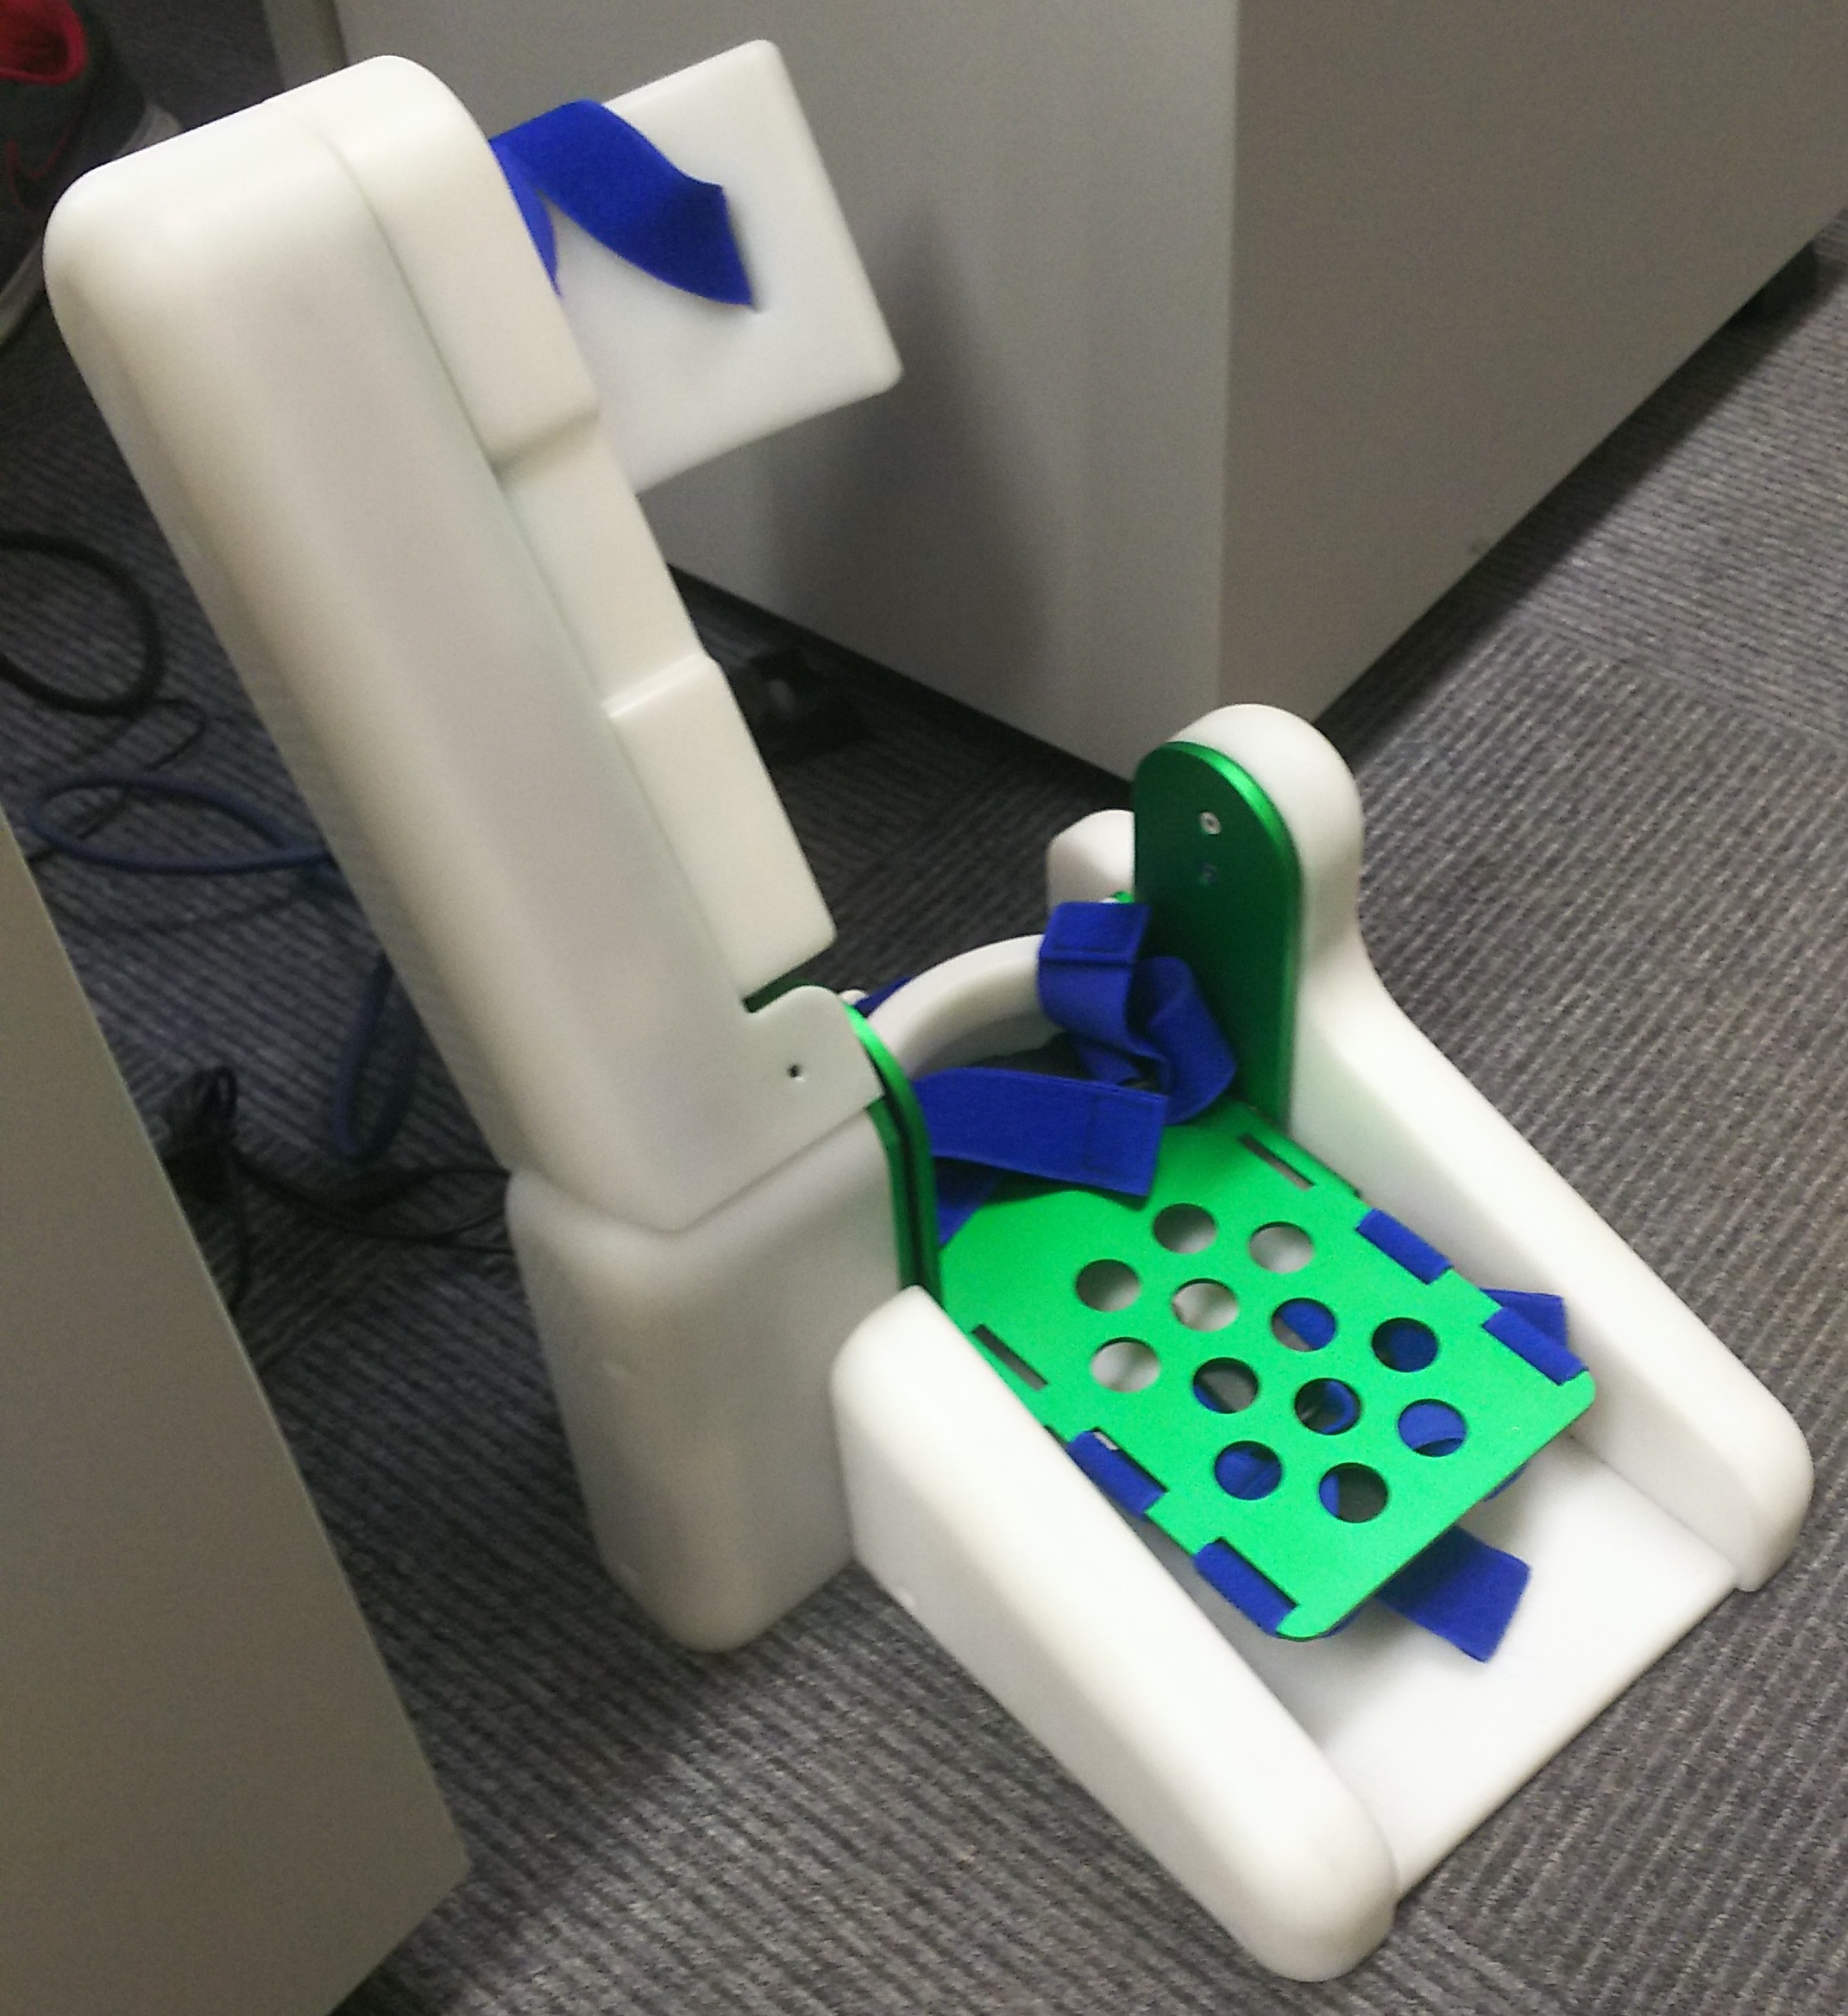
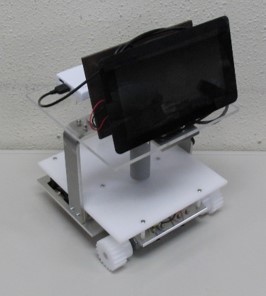
The left figure shows the rehabilitation support robot for exercise therapy developed in our laboratory. It is a small robot that is easy to carry and can train arm extension and the anterior tibial muscle which is important for walking. In addition, by visualizing the force information obtained by the force sensor and reaction force observer, you can visually determine the force you are producing. This biofeedback can improve the rehabilitation effect.
Reference material
[in Japanese]前脛骨筋の張力を可視化するバイオフィードバック型筋力トレーニングシステム
Autonomous robot motion generation
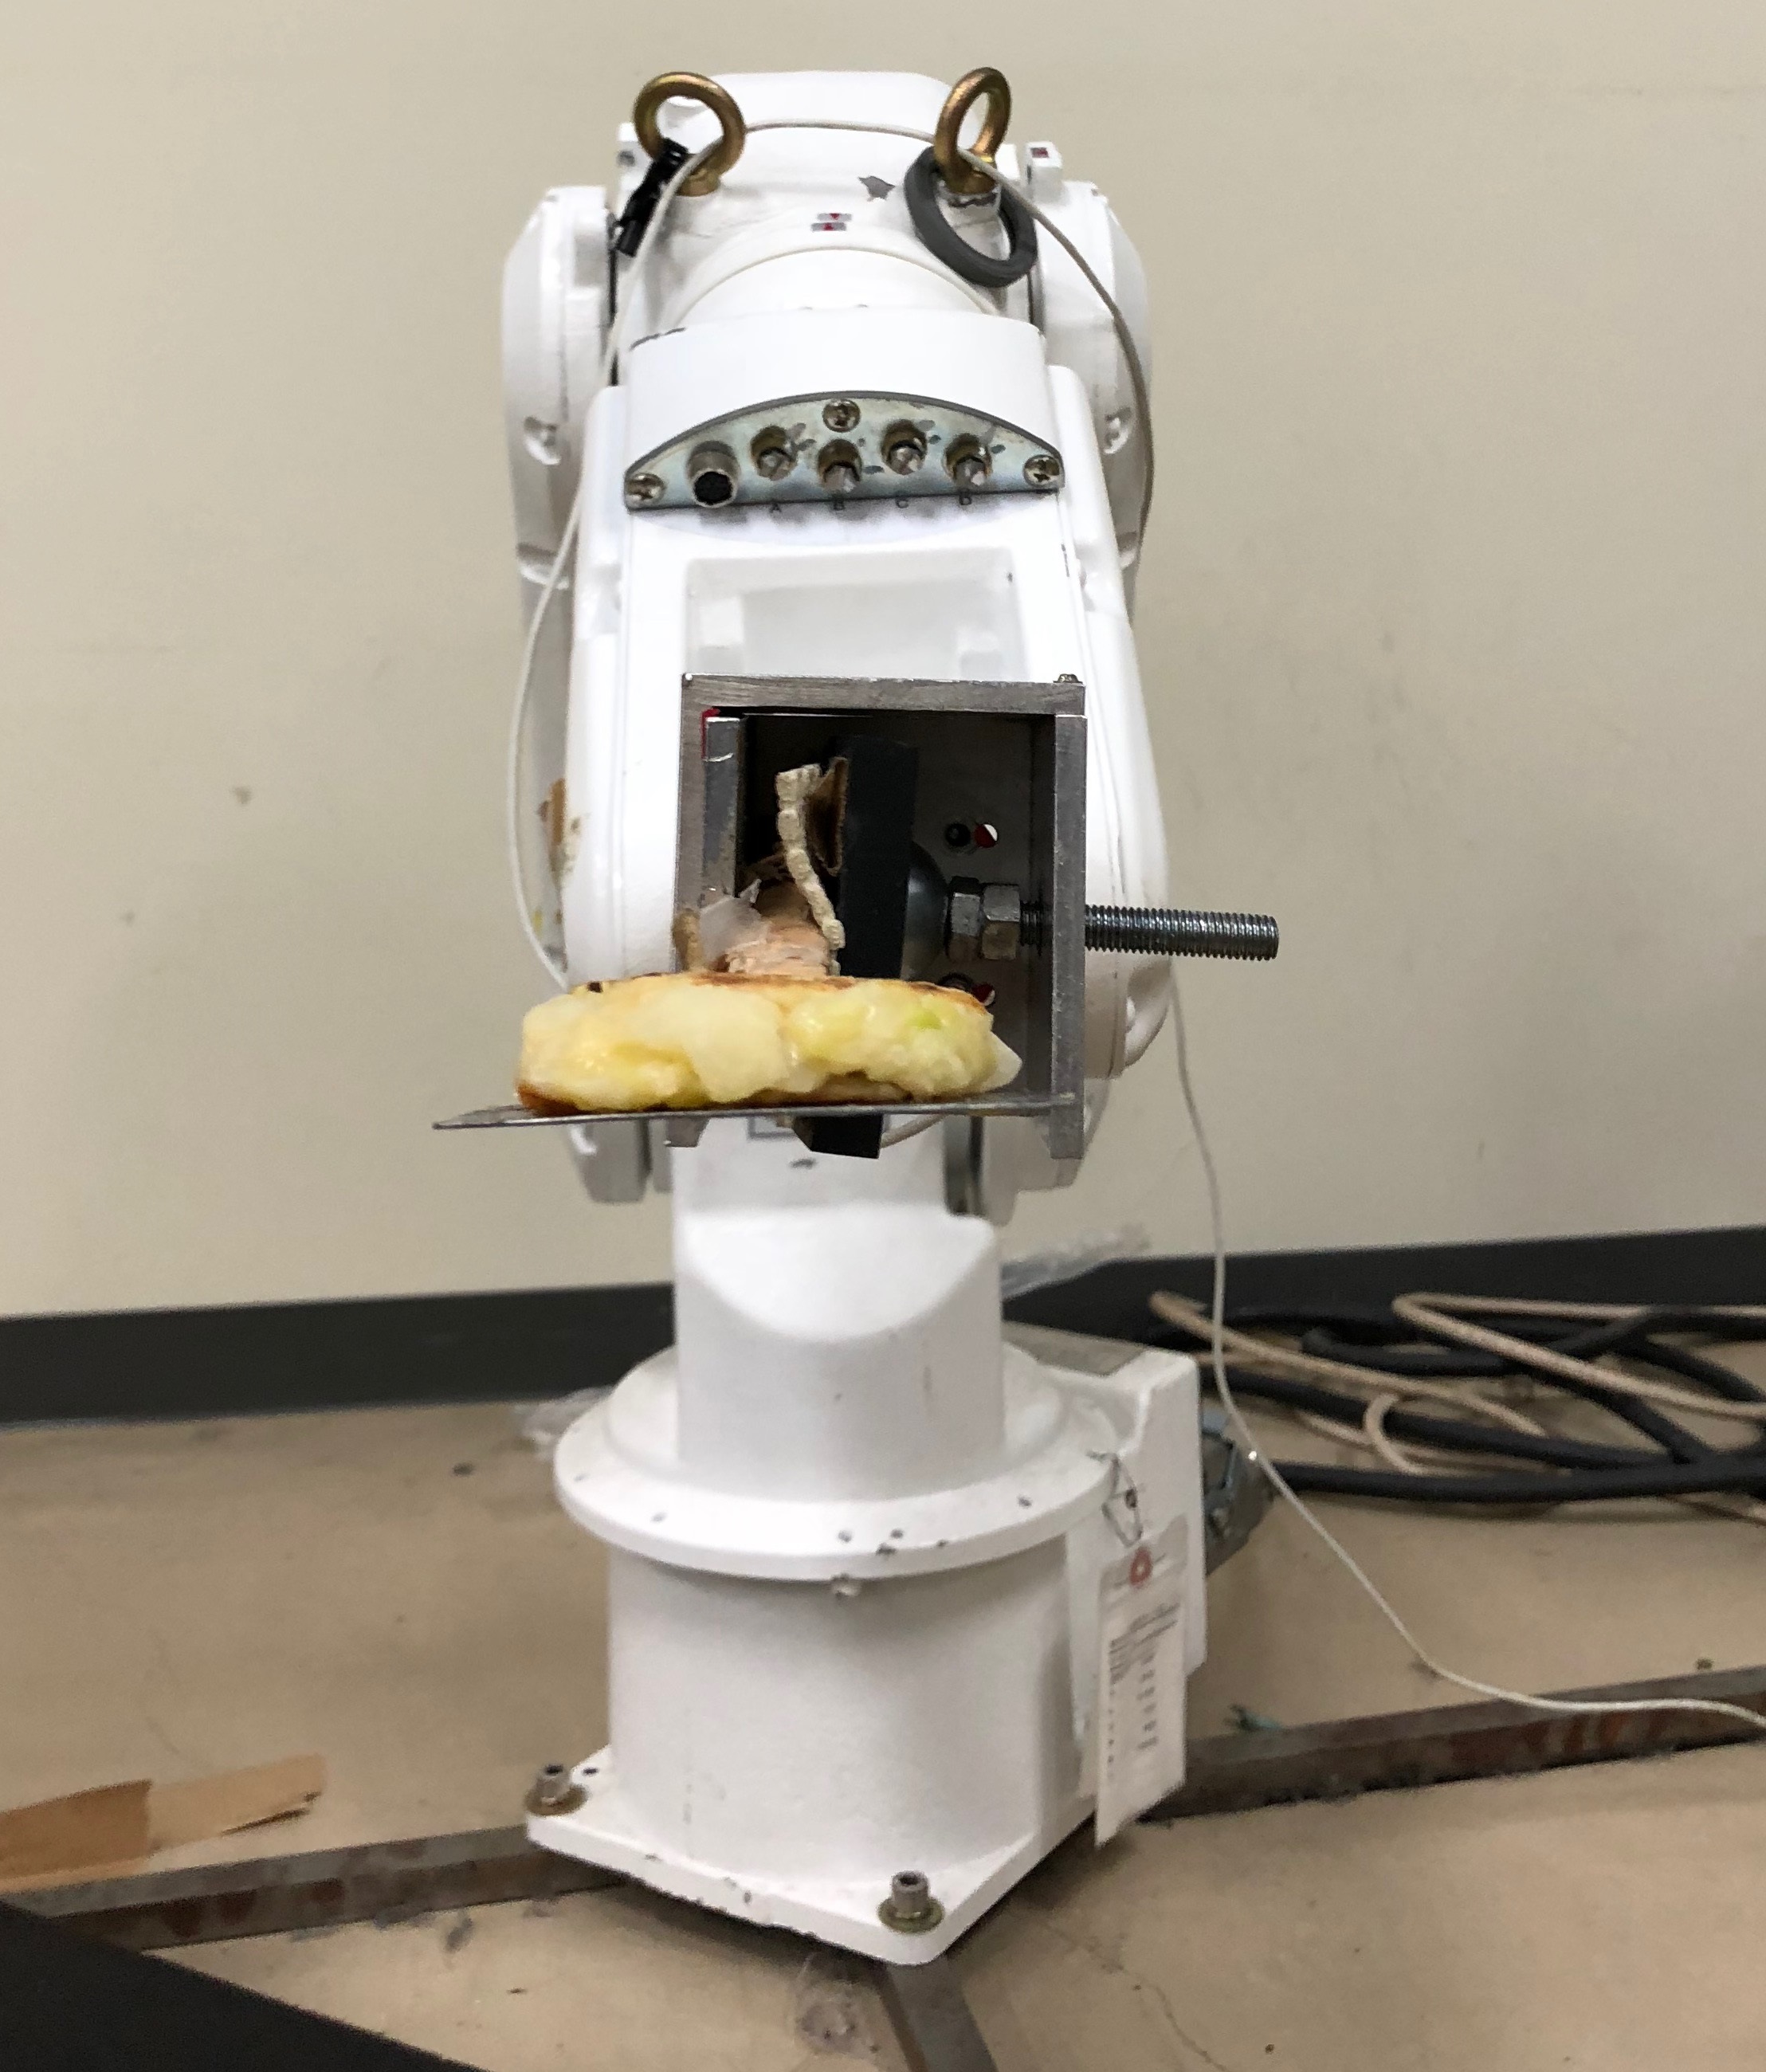
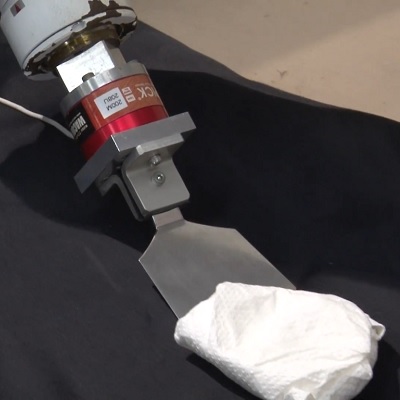
Turn over of pancakes
The figure on the left shows the robot used for verification of this autonomous motion generation research. When turning over the pancake, it is necessary to manipulate the acceleration so that it does not fall off the spatula. Therefore, it is difficult to simultaneously operate the position that is the time integral of acceleration. We solve this problem by using a neural network.
Since neural networks are expandable, we are also researching autonomous motion generation for other motions such as assembly task.
Reference material
[in Japanese]ダイナミックな技術動作を学習するロボット